Research
I study how robots compose learned skills and carry them through in the physical world. My work connects policy evaluation, failure diagnosis, and reliable robot systems.
RoboCombine
Exploring the Limits of Combinatorial Generalization in Embodied Manipulation
Xupeng Zhang, Yantai Yang, Chang Guo, Zhaokai Yin, Zhipeng Zhang
NeurIPS 2026 · Evaluations and Datasets Track Accepted · Poster
Preprint / Code / Dataset / Video
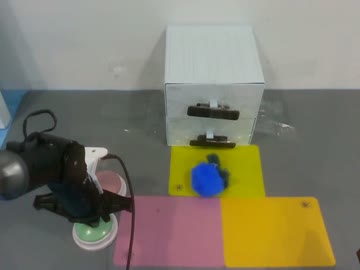
An atomic-only recombination benchmark with 19 held-out skill compositions. HSE diagnoses execution and handoff failures; PRTI improves robustness using handoff-like start states.
InfiniteVGGT
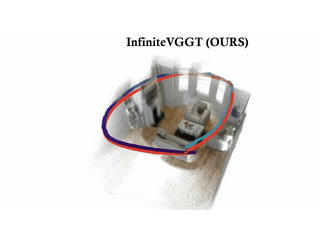
InfiniteVGGT: Visual Geometry Grounded Transformer for Endless Streams
Shuai Yuan, Yantai Yang, Xiaotian Yang, Xupeng Zhang, Zhonghao Zhao, Lingming Zhang, Zhipeng Zhang
arXiv
A manuscript on visual geometry for streaming input.
LatentRisk-VLM
LatentRisk-VLM: Failure-Guided Representation Editing for Frozen Vision-Language Models
Ke Lu, Xupeng Zhang, Jiawei Gu, Chaomeng Chen
Submitted (under review)
A manuscript on failure-guided representation editing for frozen vision-language models.
Research & engineering
VLA skill composition & handoff robustness
AutoLab-SAI, SJTU · 2025 – 2026
As first author, led problem formulation, experimental design, and paper writing for atomic skill recombination and handoff robustness in VLA policies.
- Built an atomic-only recombination benchmark with 19 held-out skill compositions and proposed HSE to diagnose start-state gaps, handoff failures, and unstable downstream skill initiation.
- Developed PRTI using handoff-like starts: 18.2% Ordered SR versus 2.6% for random perturbations. Across 13 real-robot tasks with 2–5 stages, Mean Progress improved from 0.752 to 0.802, with gains on 8 of 13 tasks.
- Built an end-to-end evaluation pipeline with Spine for task setup, policy integration, batch execution, metric aggregation, and reproducible analysis.
Doogle: Distributed CyberDog2 Runtime
Core developer · Aug 2026
A heterogeneous PC–robot runtime integrating perception, planning, and motion control.
- Unified sensor and control interfaces, with independent deployment, restart, recovery, and cross-machine tracing. Adopted by three competition teams, earning two first prizes and one second prize in the 2026 Xiaomi Cup intelligent-systems competition.
- Improved critical image-processing throughput from approximately 4.3 FPS to 15.1–30.0 FPS.
- Replaced the C++–ZMQ–Python image pipeline with a C++ Camera API and seqlock shared memory. Real-robot stress tests reduced peak CPU by 37.1% and peak RSS by 42.1% relative to ZMQ.
Code & documentation ↗
Tactile data acquisition for human–robot alignment
Undergraduate thesis · Sep 2026 – Present
Ongoing work on unified human-hand and robot-gripper acquisition interfaces with a 9-axis tactile sensor.
- Completed acquisition-software interface verification documentation and a review of relevant papers and code.
- Planning episode-based RGB, proprioception, tactile, and expert-action storage with dual timestamps, dropped-frame checks, and calibration versioning.
- Planned validation: pair human and robot samples, learn aligned tactile encoders, integrate with ACT, and evaluate transfer under equal robot-demonstration budgets.